

Touch · Think · Trust
Building Physical AI That Works in the Real World
Robots that only see are not ready for the factory. Learn how an embodied AI brain, smart gripping, and a humanoid platform with safety built in come together to take Physical AI from demo to deployment.
Three bottlenecks. Three companies. One pipeline from lab to work floor.
Physical AI faces three bottlenecks, and each of our three companies specializes in one. In this webinar, we come together on one stage to explore how combining our core capabilities connects the full path from lab model to safe human-robot collaboration.
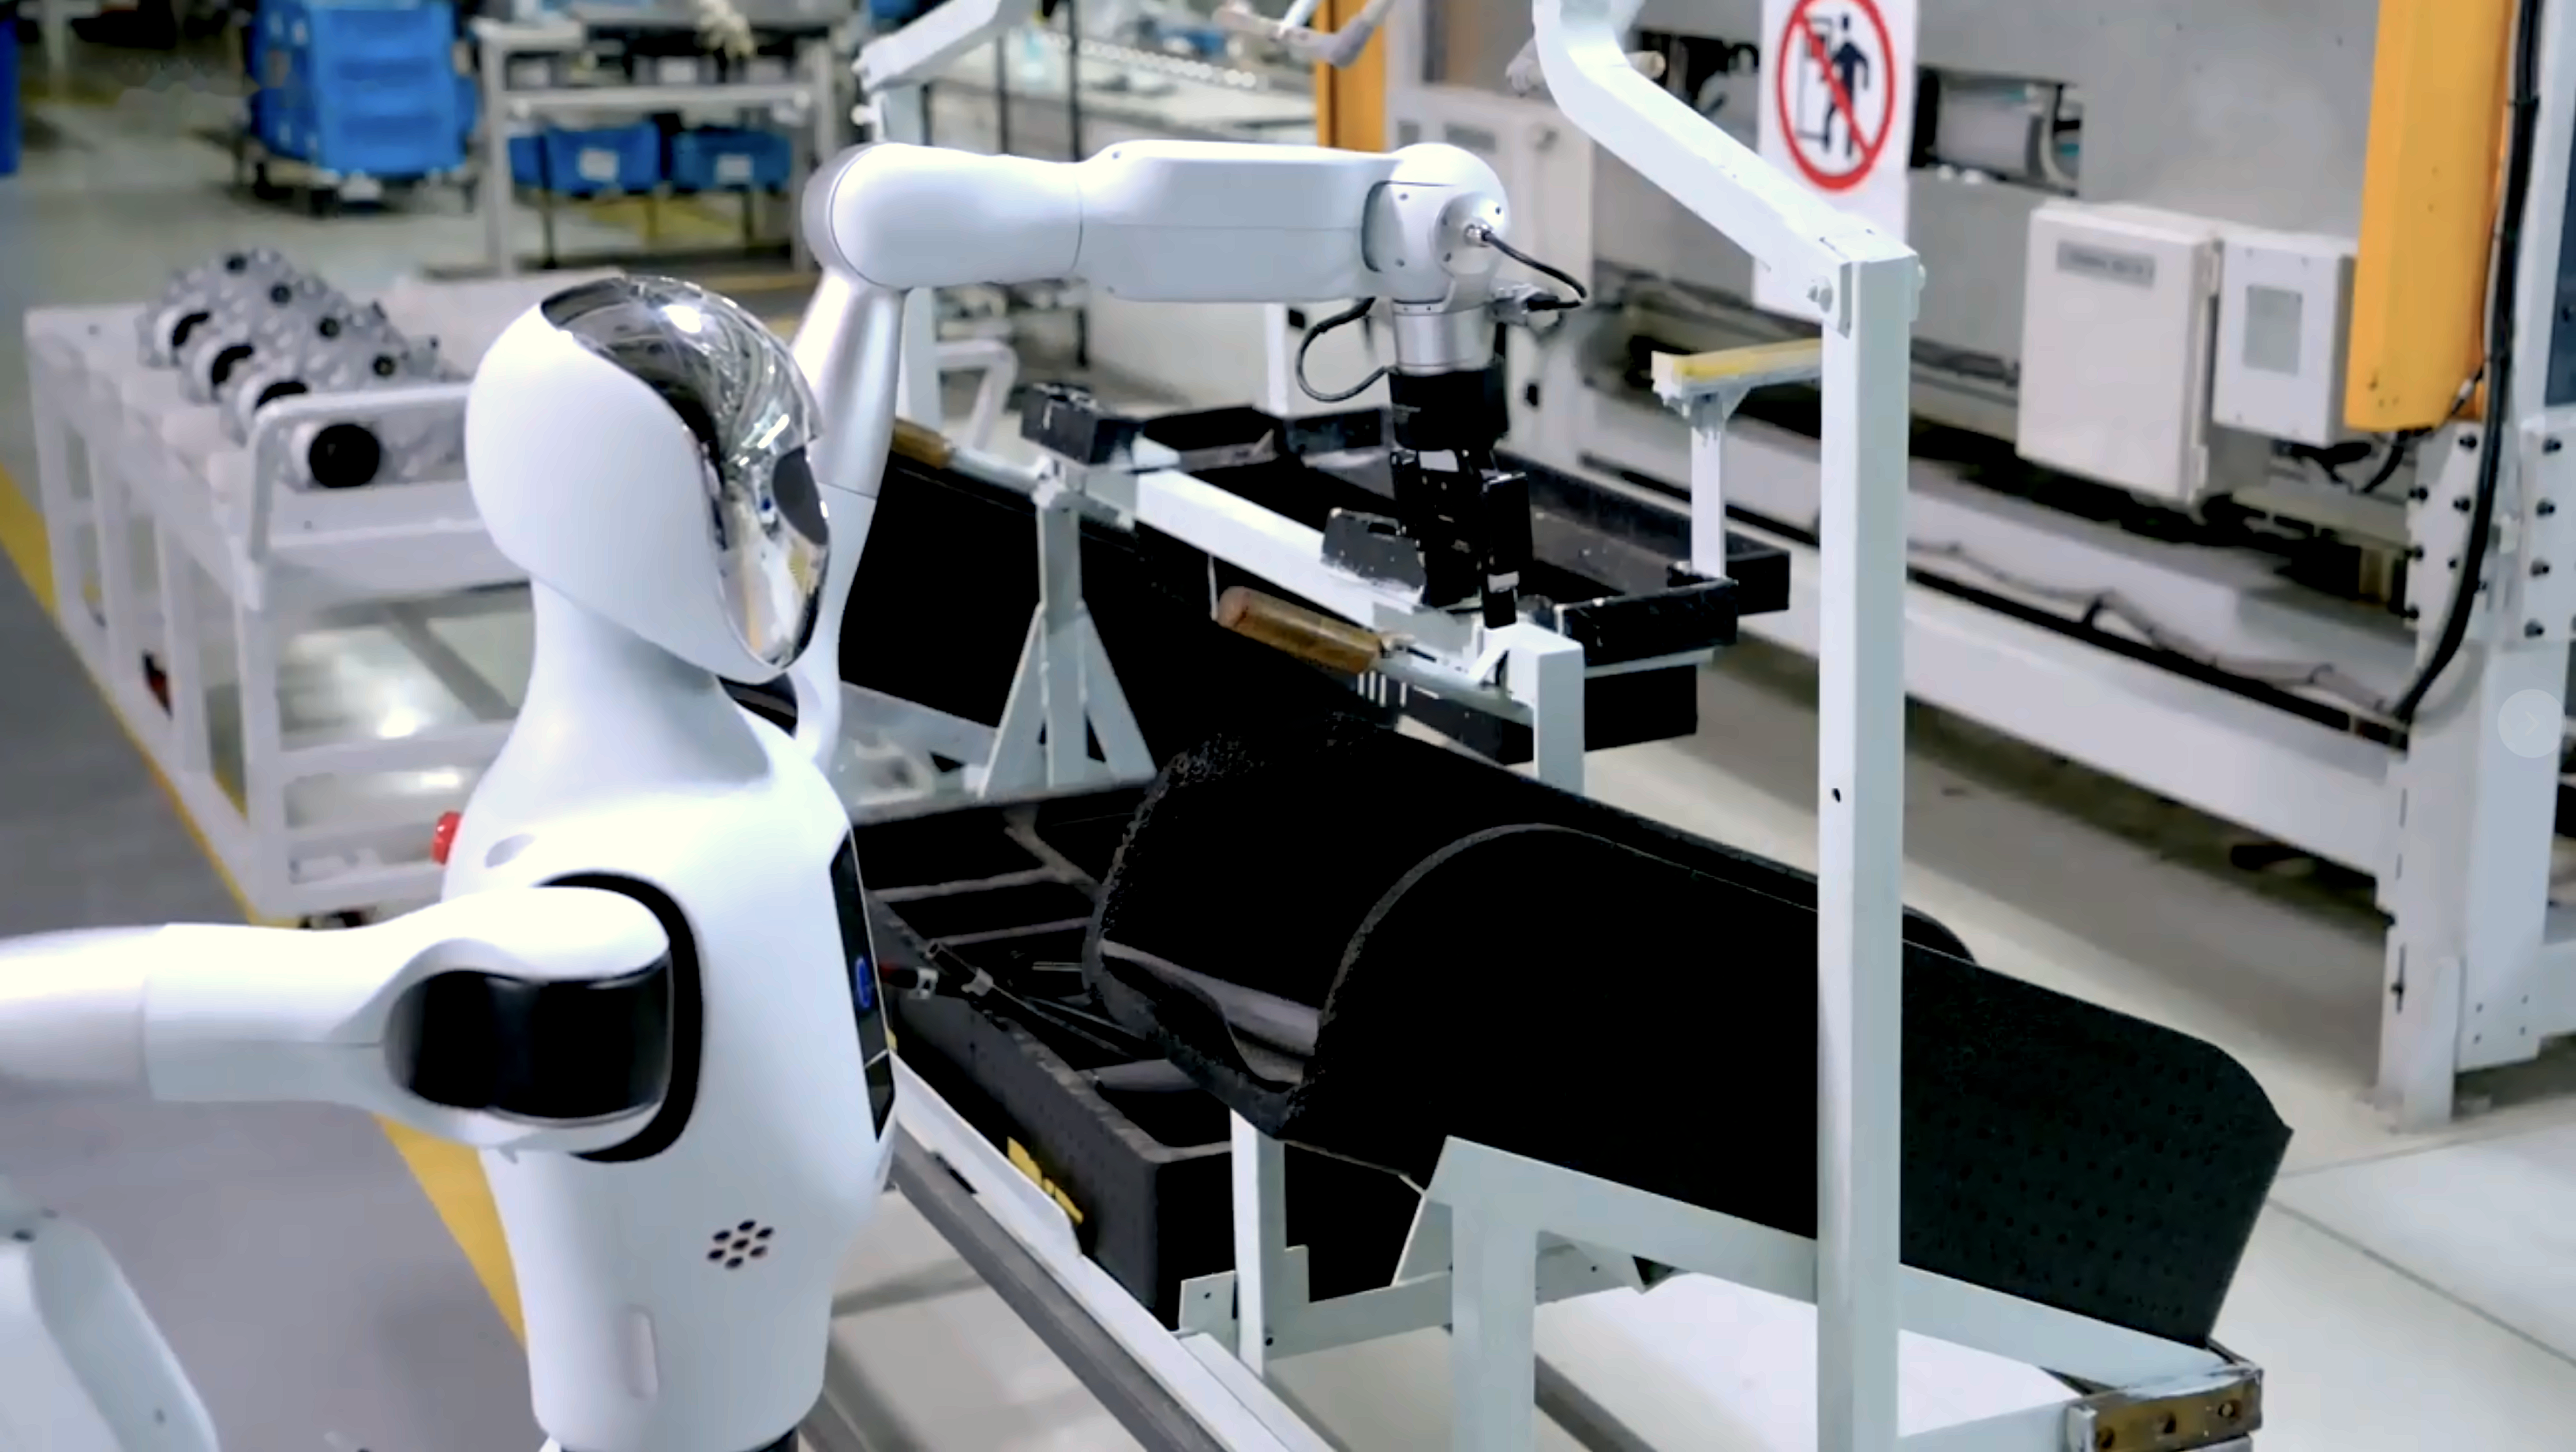
The common thread is real-world manipulation: Galbot provides the embodied brain and the humanoid platform, Robotiq gives the fingertip its sense of touch and grasping capability, and Safetics makes the body ready for research, with humanoid control packages and safety built in from day one.
TSF-85 tactile fingertips, FT-300-S force-torque sensor, adaptive grippers, and Contact Core (Isaac Sim assets, ROS 2, contact-rich data API).
G1 wheeled humanoid with swappable end effectors, and AstraBrain, a whole-body embodied foundation model, including AstraBrain-Dex for dexterous hands.
Humanoid Control Packages for research labs: bipedal locomotion and a VLA data collection system, with contact safety and risk assessment built in.
A capable brain, a hand that can feel, and a platform ready to apply the latest technology
A humanoid that perceives, plans and controls its arms, hands and base as one system can adapt to new tasks and keep working when the environment changes.
Vision alone misses what happens on contact, where force, pressure and vibration decide if a grasp holds. The TSF-85 reads pressure, vibration and orientation right at the fingertip, backed by an industrial gripper built to endure millions of cycles in continuous production.
Humanoid Control Packages give research labs bipedal locomotion and a VLA data collection system, on a safety-first setup, so day one goes to research.
See how these three layers combine to move Physical AI from demo to deployment.
Meet the experts
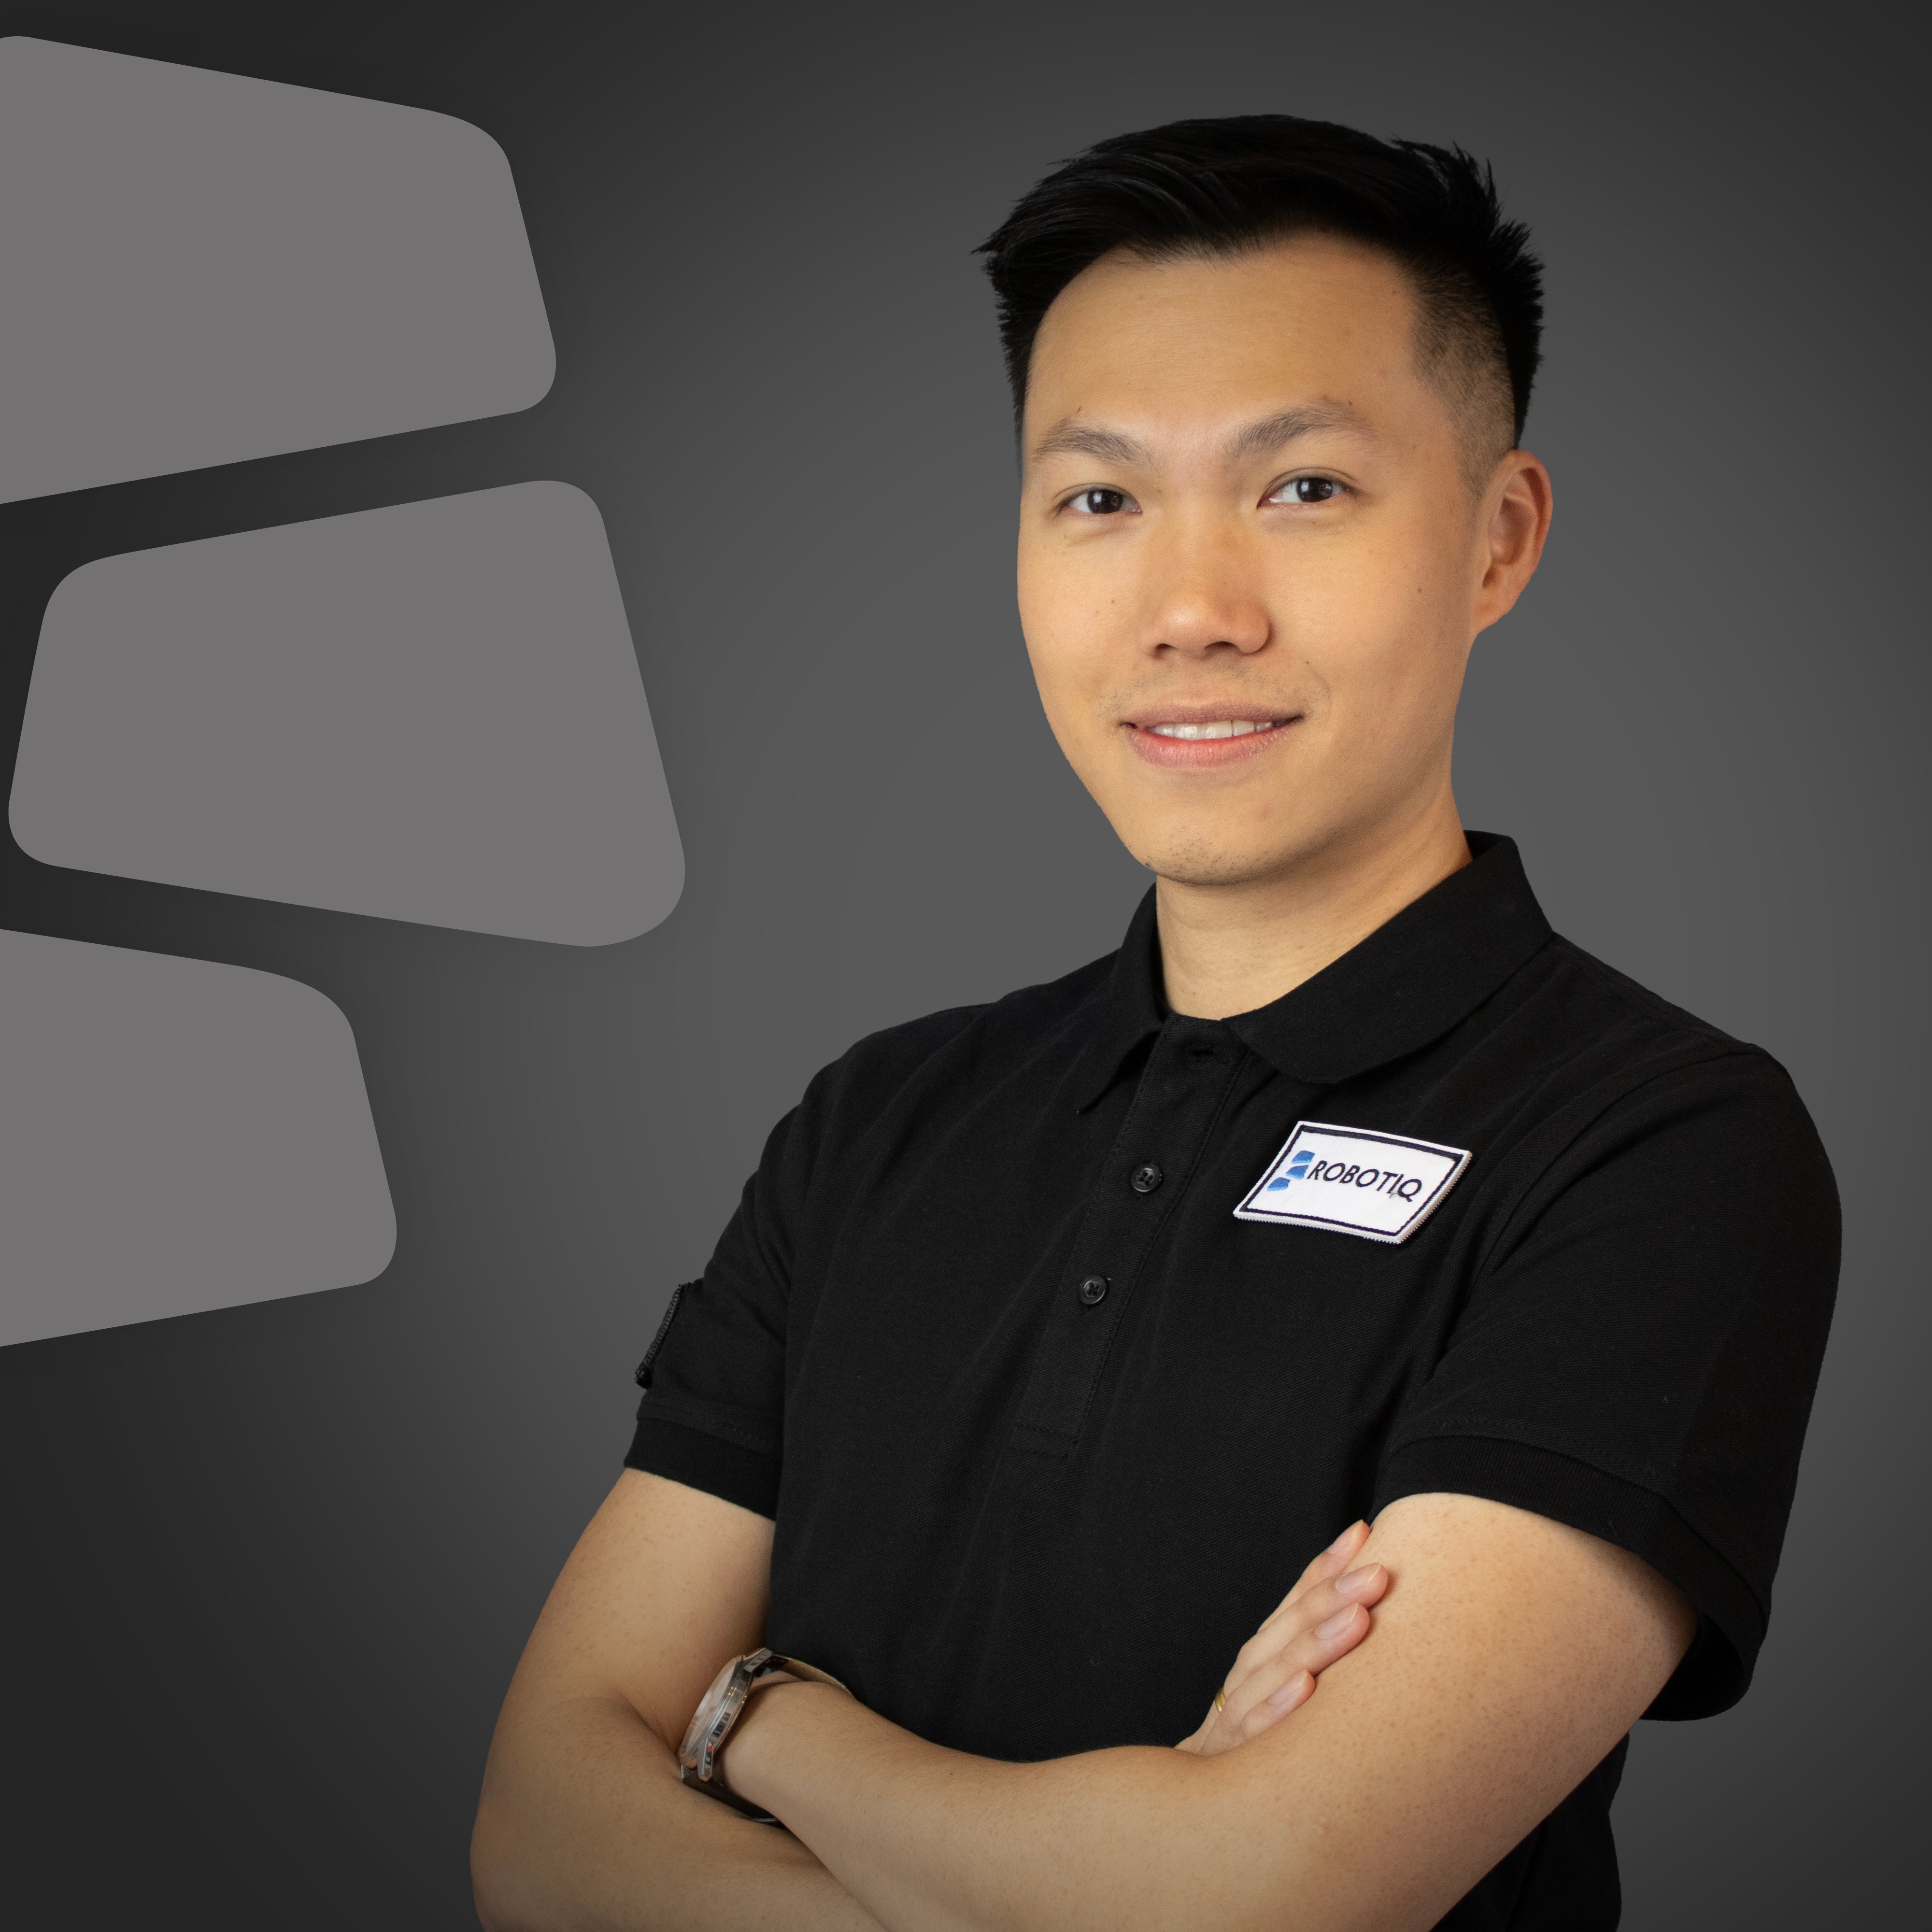
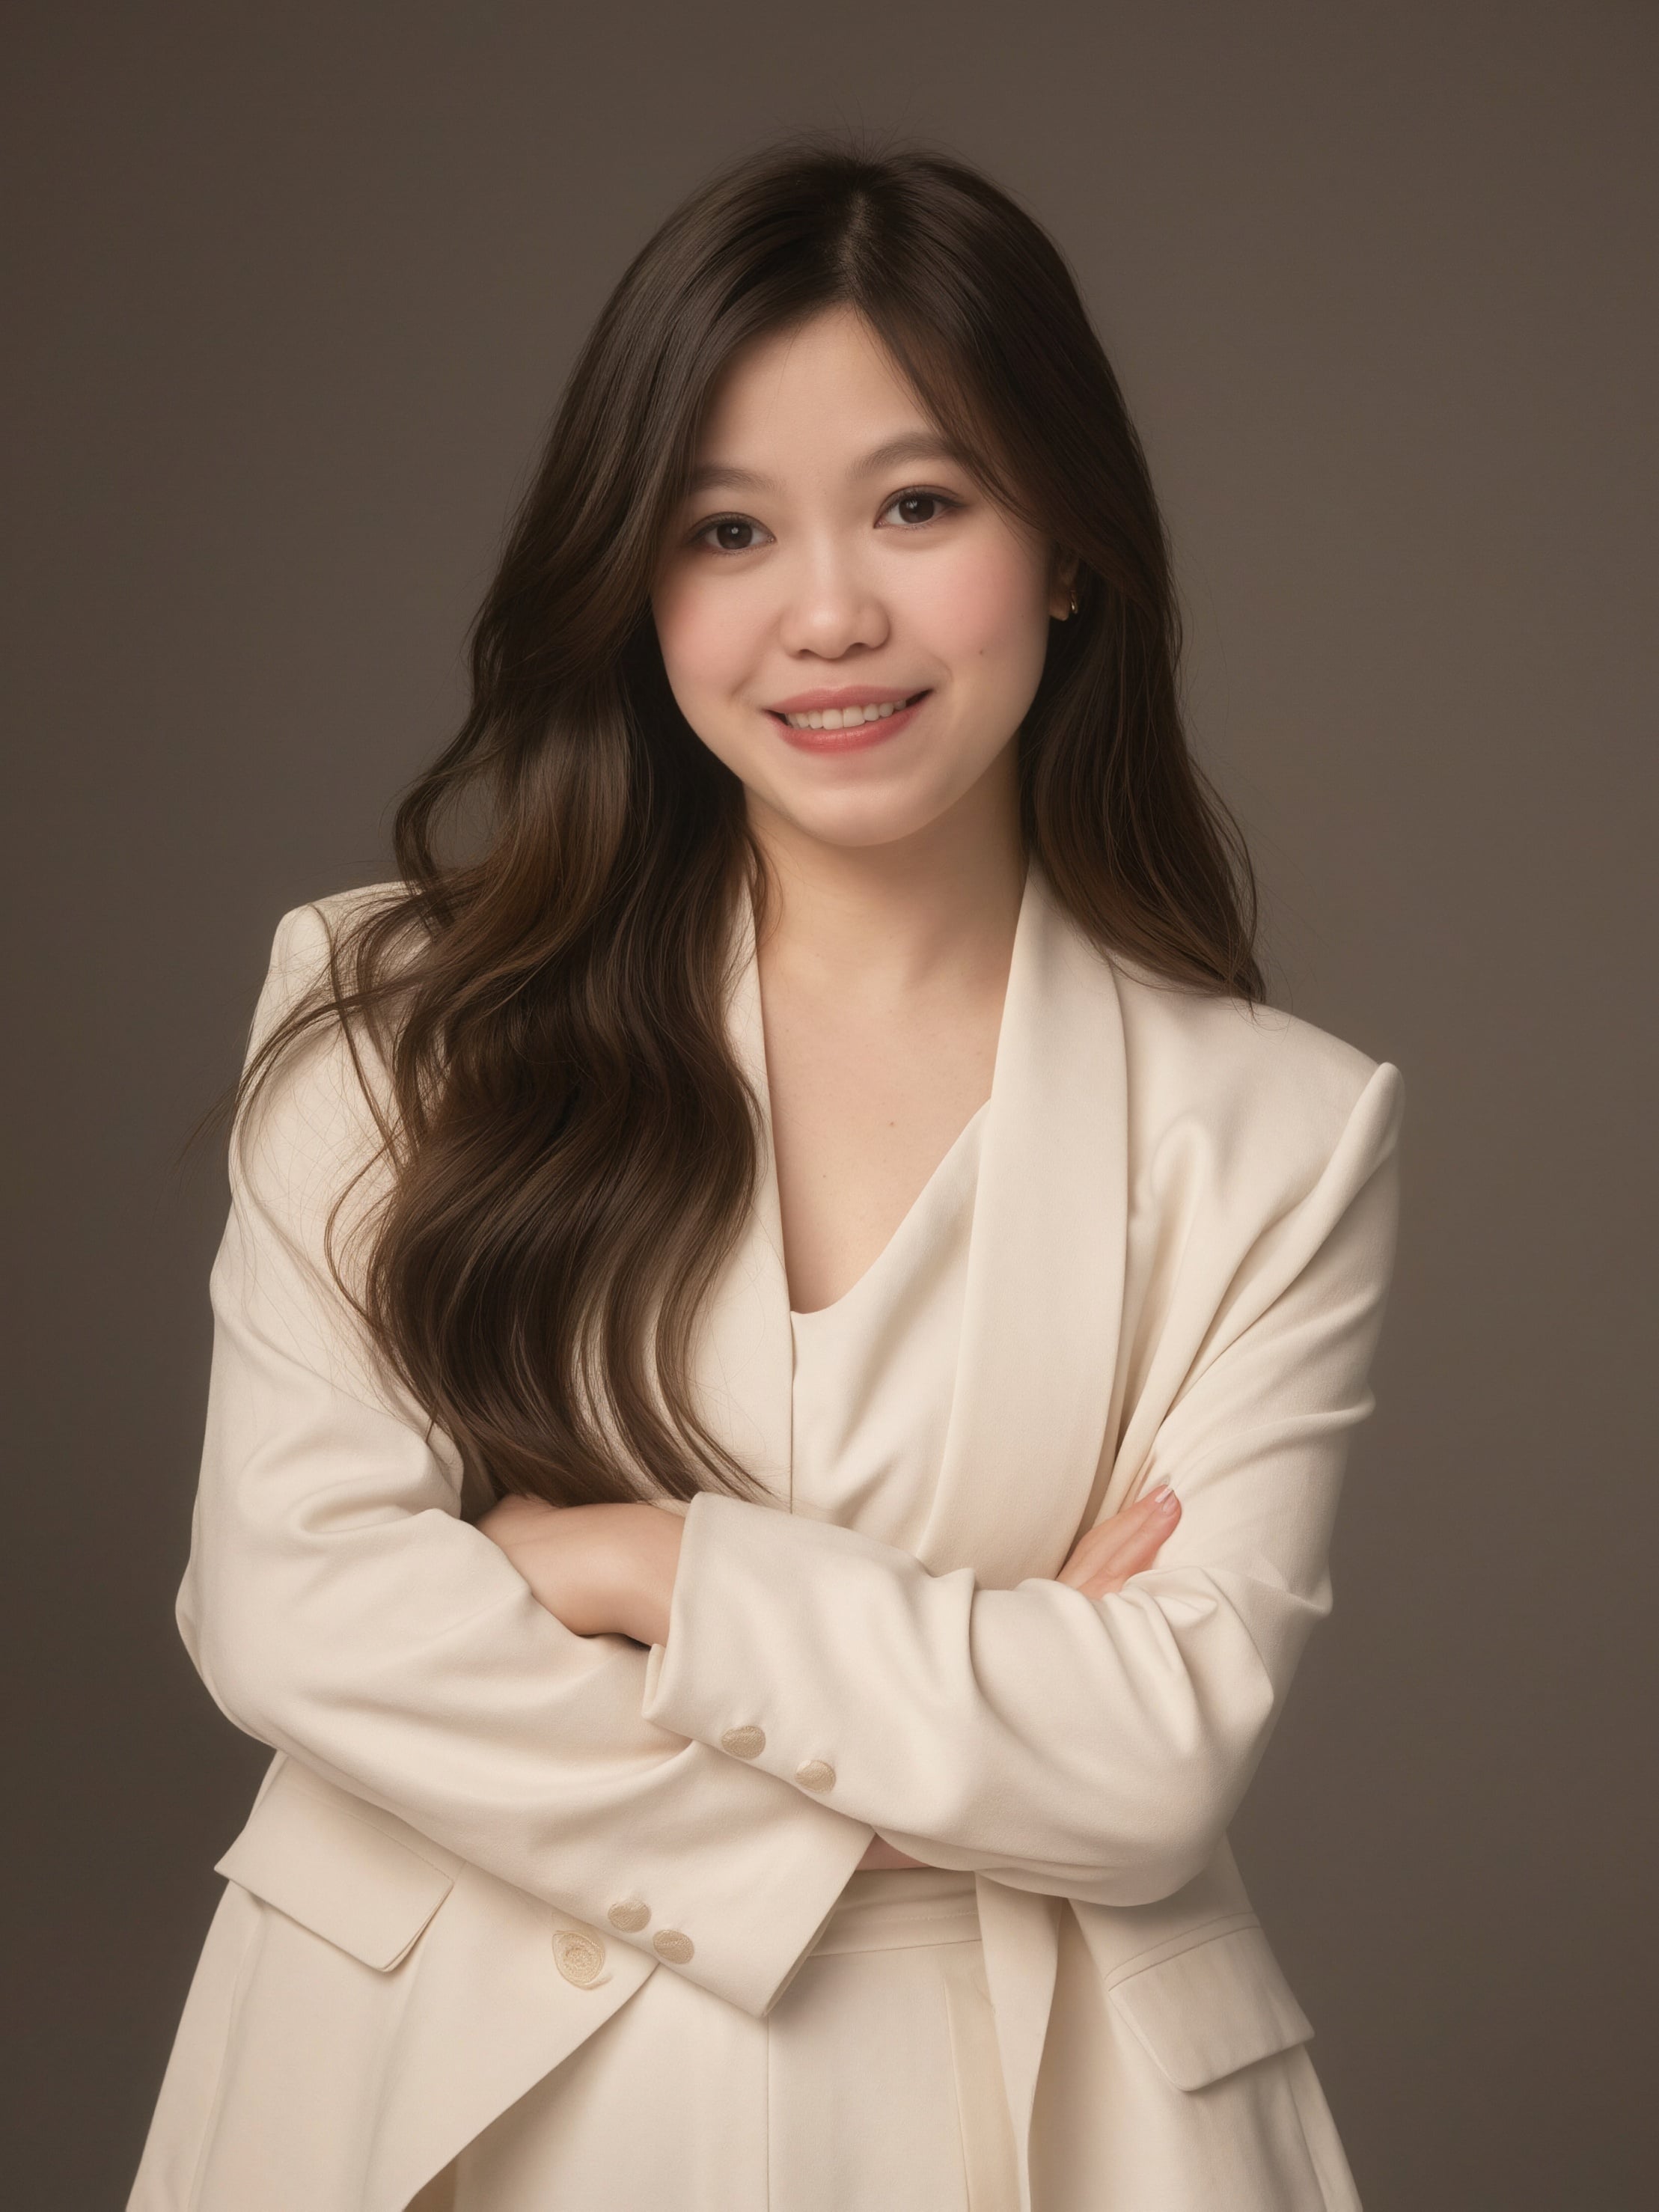
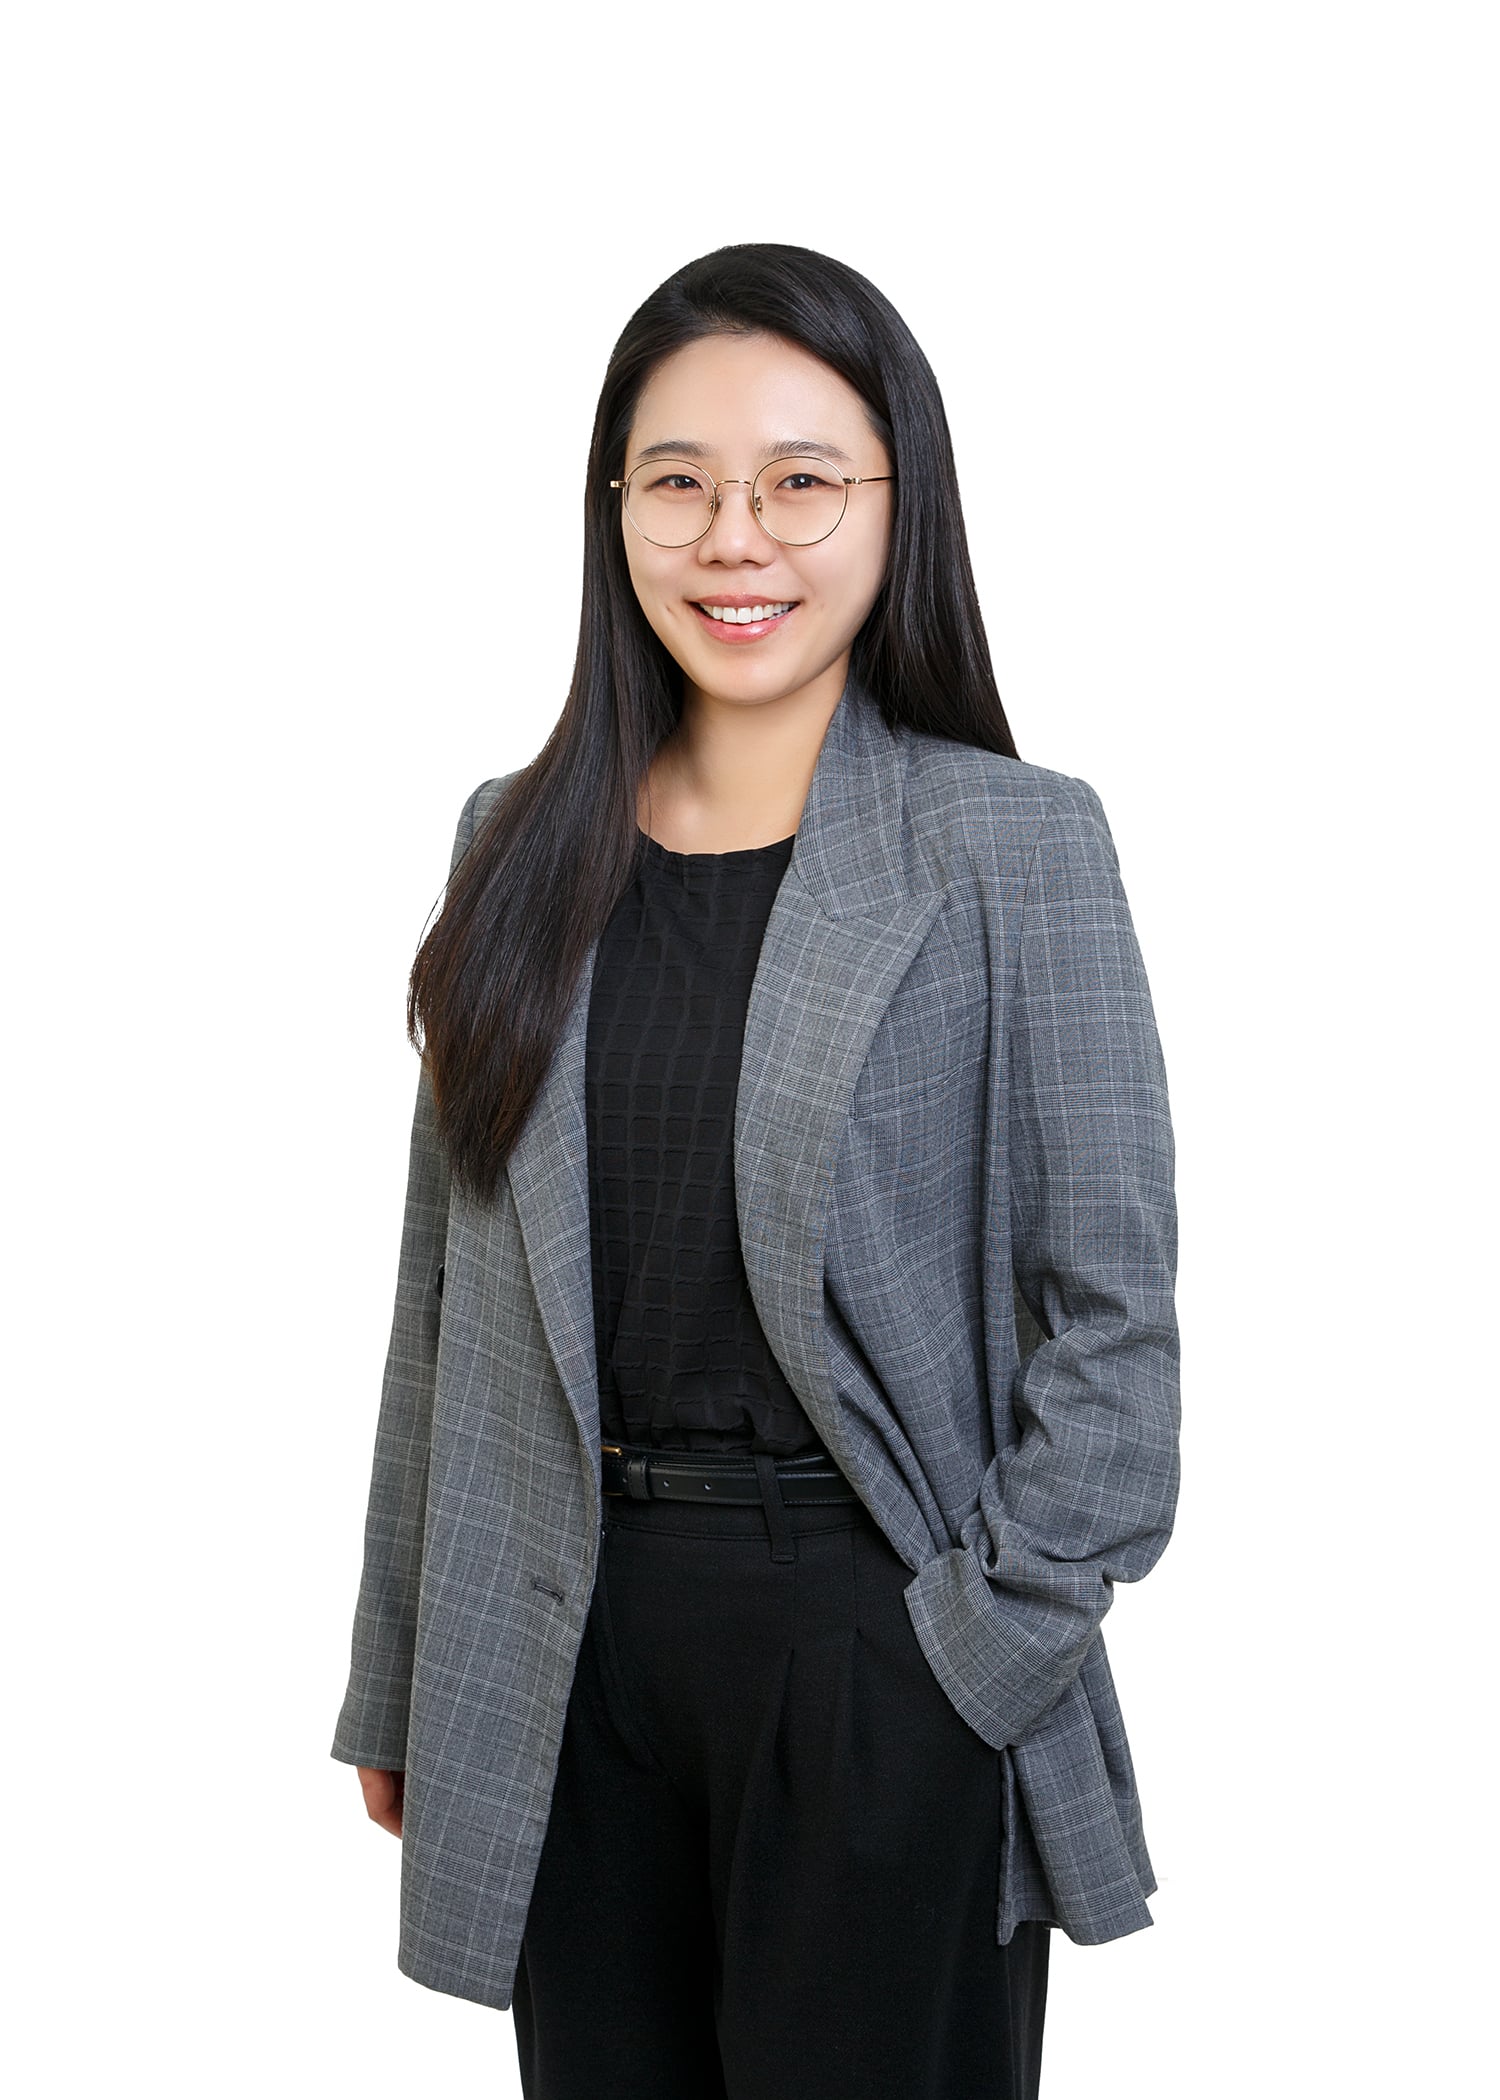
60 minutes, three sessions, live Q&A
- The hardware foundation: why 30,000+ successful deployments matter for AI reliability and continuous data collection (high uptime, IP-rated durability).
- Unlocking the “hand” data: how TSF-85 tactile sensors (pressure, 1000 Hz vibration, orientation) extract rich, multimodal data from the grippers you already trust.
- Sim-to-real made seamless: using Robotiq’s open-source Contact Core (Isaac Sim assets, ROS 2, contact-rich data APIs) to train models faster and deploy them on proven hardware.
- One brain, whole-body intelligence: how Galbot’s AstraBrain unifies perception, reasoning, planning and whole-body control for coordinated humanoid behaviors.
- Building generalist embodied foundation models: Galbot’s approach to robot intelligence that adapts across diverse tasks and environments.
- From models to real-world autonomy: how generalist intelligence becomes practical autonomy in retail, industrial, logistics and other real-world scenarios.
- Why humanoid research stalls before it starts: teams spend valuable time just getting a humanoid to stand and walk reliably, and every fall puts the robot and the people around it at risk.
- A humanoid that stays on its feet: how the Bipedal Locomotion Package recovers balance after pushes and collisions and walks steadily on slopes and uneven ground.
- Day one goes to your research: how the VLA Data Collection System lets your lab start collecting training data right away.
Built for teams taking robots out of the lab
- Robotics and AI researchers and start-ups building manipulation or VLA models
- Humanoid and mobile-manipulator developers
- System integrators and automation engineers moving into AI-based cells
- Manufacturing and R&D leaders evaluating Physical AI pilots
- Universities and research labs
UTC+8
JST / KST
IST
Take Physical AI from demo to deployment
Join Robotiq, Galbot and Safetics live on Wednesday, 2 December 2026 at 14:00 (UTC+8).
Register nowCan’t join live, or need localized captions? Register anyway to receive the on-demand replay.